Hi there!

I'm Kağan Küçükaytekin.
Little bit hard to pronounce, right?
You can call me "Kaan" (hear it), or just "K" if that's easier.
If you prefer a more formal tone, you can call me "Mr. Aytekin".
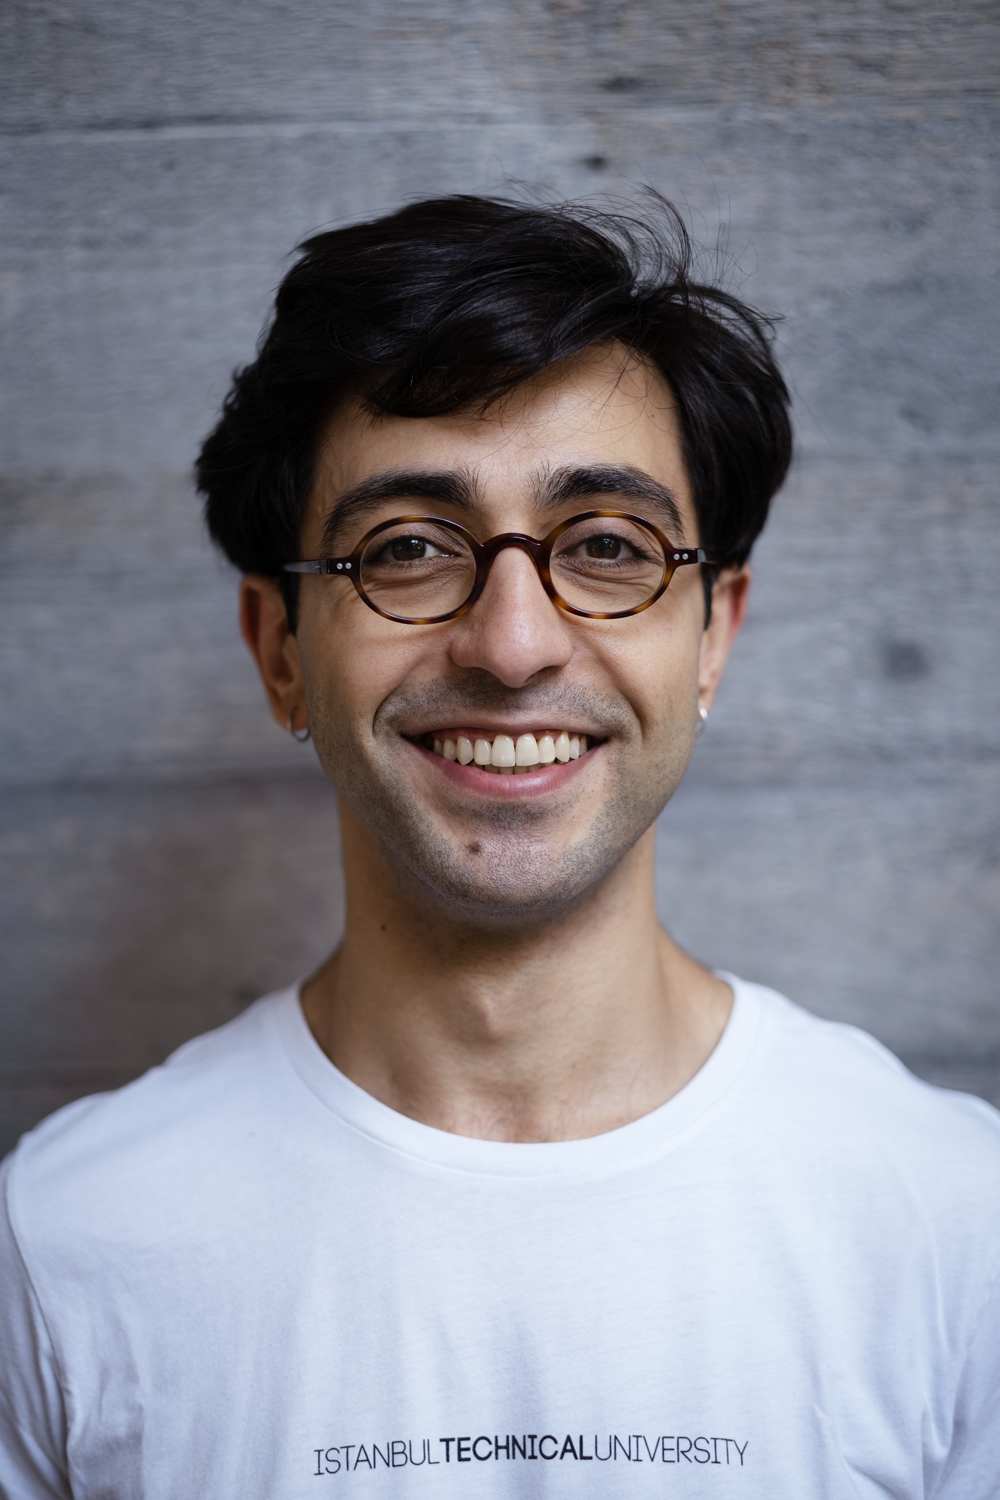
Kağan K. Aytekin - Machine Learning and Robotics Engineer

Featured Projects

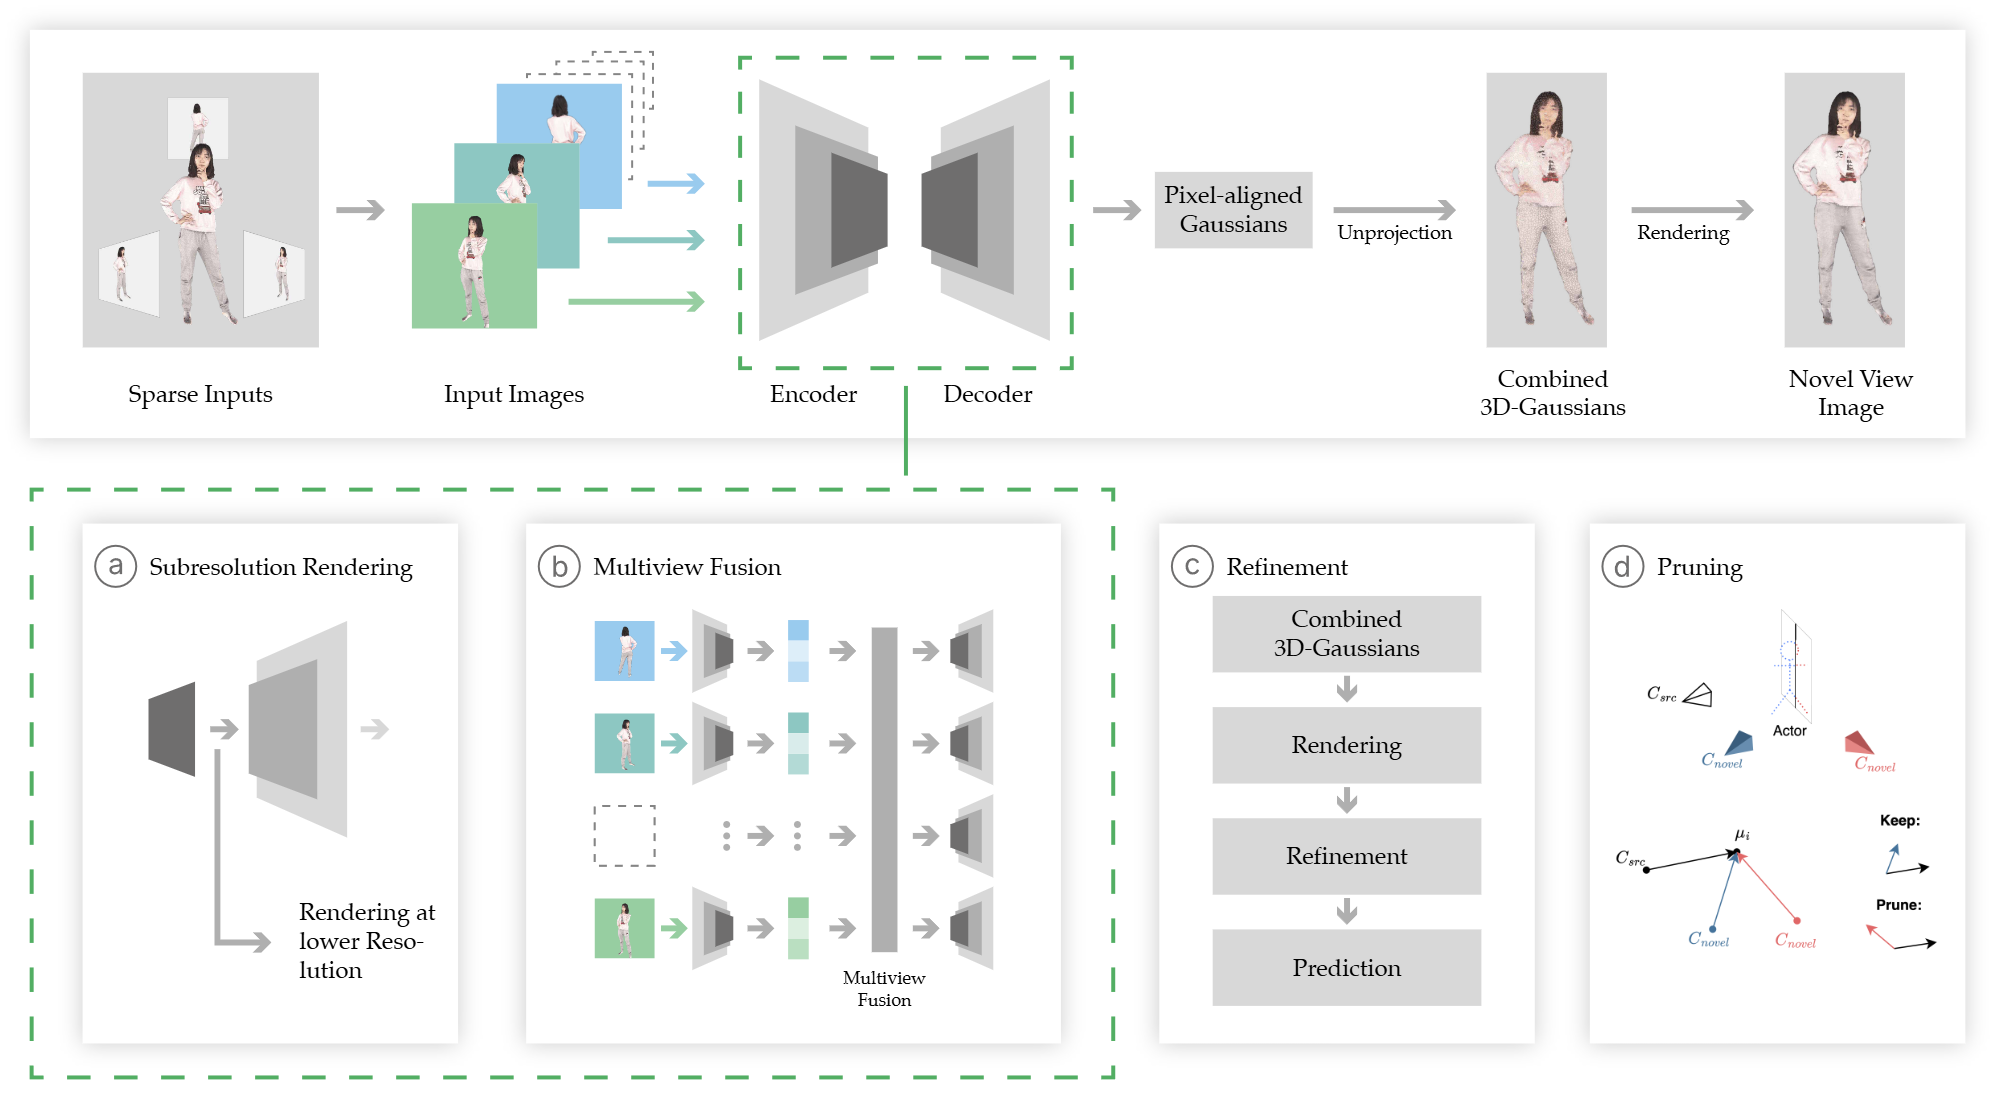
Master Thesis - Generalizable Human Novel View Synthesis with Gaussian Splatting

Master Thesis: Generalizable Human Novel View Synthesis with Pixel Aligned Gaussian Splatting

A real-time capable pixel-aligned Gaussian splatting-based method for realistic novel view synthesis of humans from sparse input images, enhancing flexibility by reducing reliance on priors and preprocessing.

Pytorch Slurm OpenCV Open3D NeRFStudio Neural Rendering 3D Reconstruction Gausian Splatting Transfer Learning
Sony Logo CAMP Chair Logo
Huawei Publication

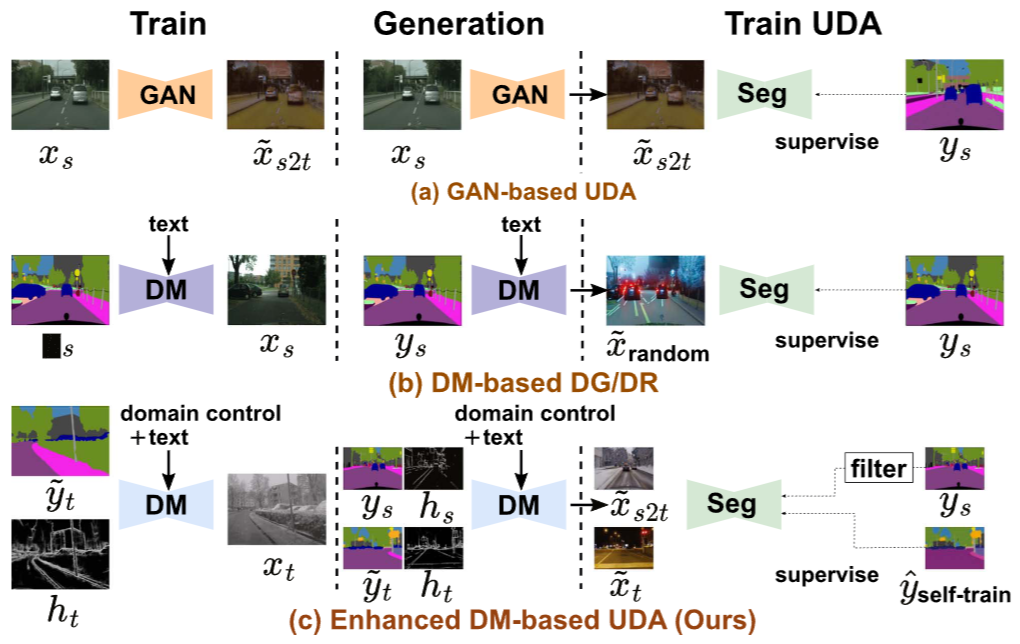
Publication: W-Control UDA

Focused on improving semantic segmentation for autonomous driving in challenging weather conditions, leveraging self-training, semi-supervised learning, and data augmentation from generative models like GANs and diffusion models.

Semantic Segmentation Distillation Autonomous Driving Generative Models GAN Diffusion Pytorch Lightning MMSegmentation MMCV MMEngine
Huawei Logo
ADL4CV Project - 3DETR-S2C

Dense Captioning for 3D Scenes with Transformers

Introduced transformers to different components of a 3D Dense Captioning pipeline to boost performance.

Pytorch 3D NLP GNN RNN GCP Transformers
TUM Visual Computing Lab Logo
ADL4R - Social Navigation with Reinforcement Learning

Social Navigation with Reinforcement Learning

Trained an agent to navigate in dynamic environments using reinforcement learning and curriculum learning.

Pytorch OpenAI Gym Reinforcement Learning Robotics GCP
DLR Logo
AT43DCV - Polarimetric Depth Estimation

Monocular Depth Estimation with Polarimetric Camera

A supervised monocular depth prediction model leveraging polarimetric characteristics of light. During the model development, particular emphasis was put on improvement of the depth estimation for photometrically challenging objects.

Python Numpy Kornia CNN's Attention U-Net
CAMP Chair Logo
Mobile Robotics Practical - Autonomous Delivery Drone

Autonomous Delivery Drone

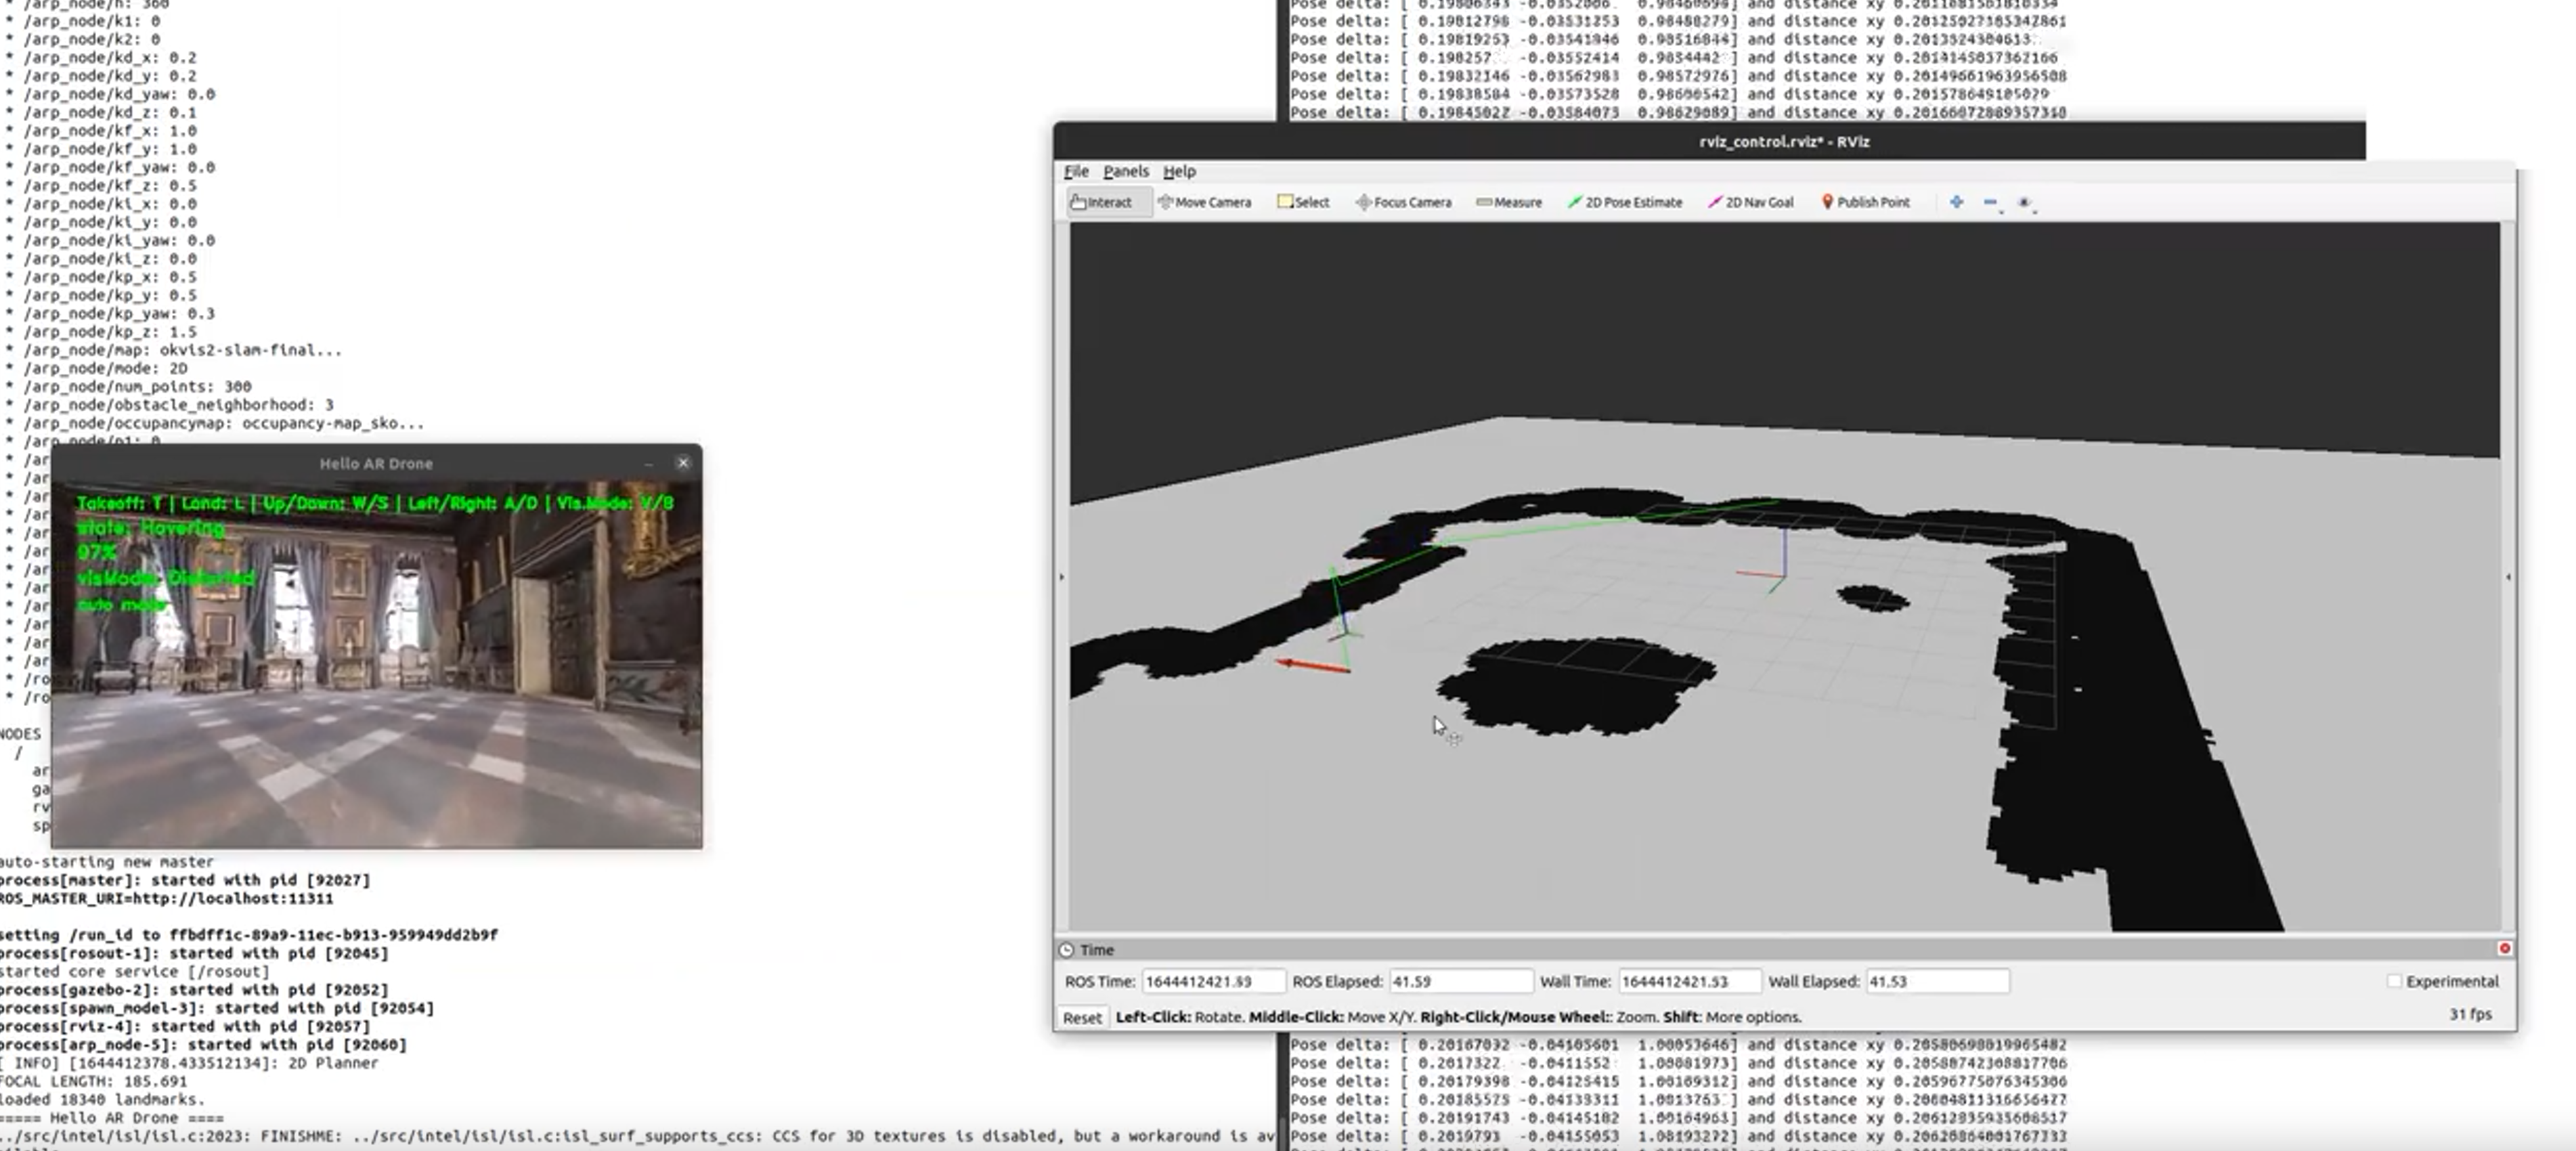
Implemented localization, sensor fusion, navigation, control, and path planning of an autonomous drone.

C++ CMake ROS Gazebo OpenCV SDL2
Smart Robotics Lab Logo
Fundamentals of Human Centered Robotics - Robothon Project

Shared Object Manipulation with Franka Robot Arms

Programming two Franka Panda robot arms to achieve collaboration in CoppeliaSim (V-REP), while avoiding self-collision and obstacles.

Go Lua V-REP Physics Simulation
MIRMI Logo
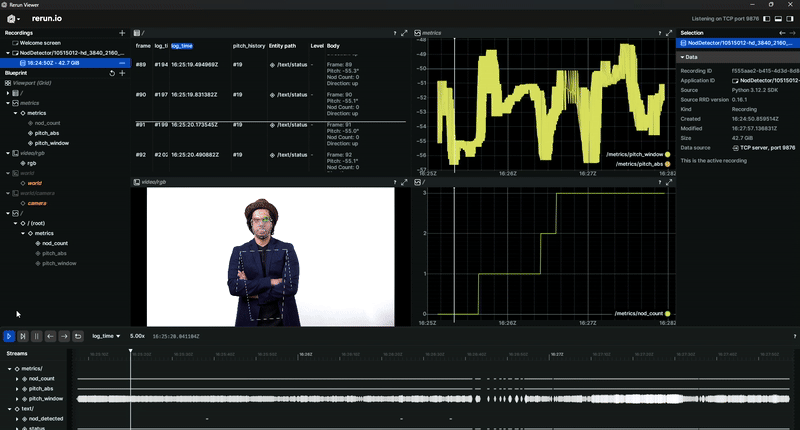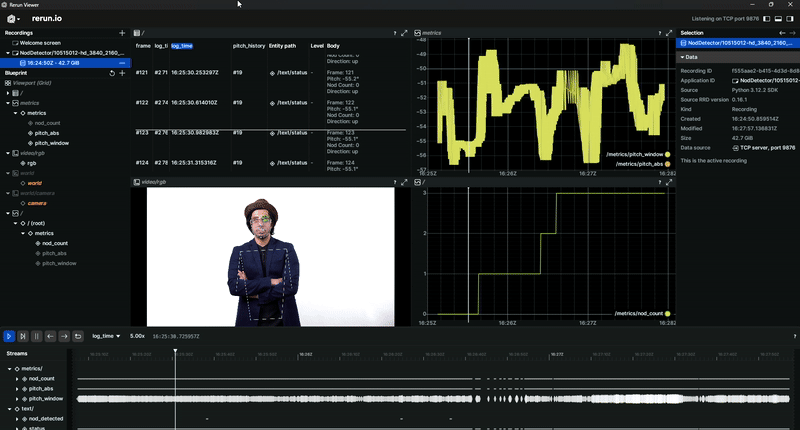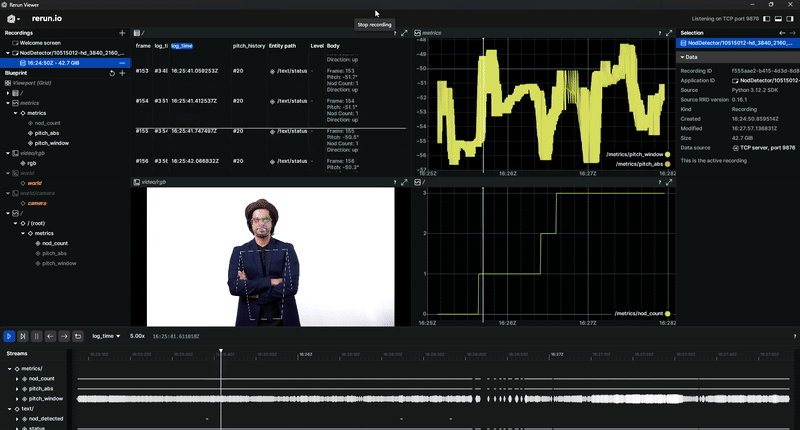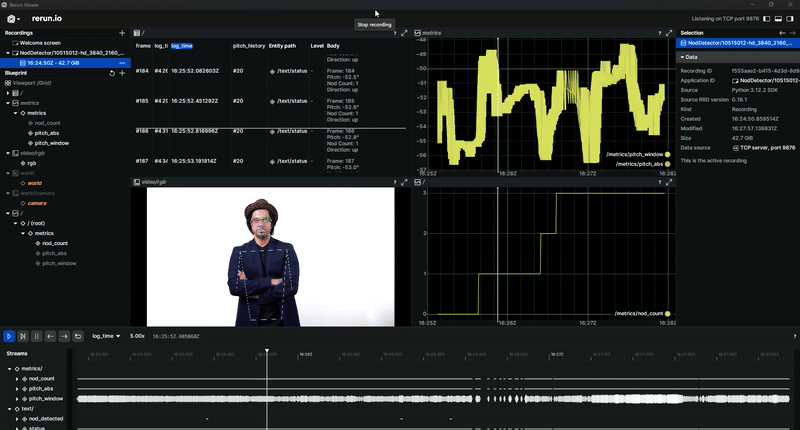
Nod Detector Data Stream

Vibe Coding a Nod Detector

Main goal here was to test the capabilities of Coding IDE's and CLI's. Used Windsurf and Claude Code for this project. Vibe coded a multi-modal data collection pipeline.

CI:Github Actions Testing:Pytest Docs:Sphinx Vis:Rerun CLI:Typer Containerization:Docker Code Quality:Black Static Analysis:Flake8 Type Checking:Mypy MediaPipe
Teleoperating 3D Printed Robot Arms

Teleoperating 3D Printed Robot Arms

As a hobby project, 3D printed, built, calibrated SO-100 robot arms. Tweaked LeRobot source code for dual follower teleoperation.

Hardware 3D Printing Teleoperation SO-100 LeRobot Builder